








Add Menu - Utilities - Rotation
Utility nodes are mainly for mathematical operations.
Add menu - Utilities - Rotation
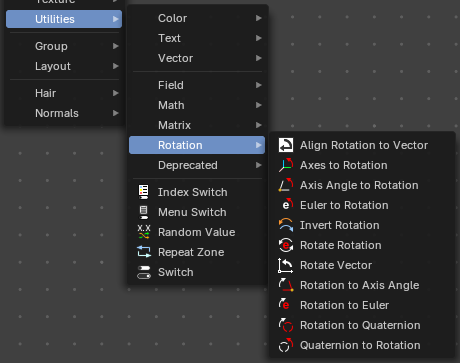
Utility nodes are mainly for mathematical operations.
Align Rotation to Vector
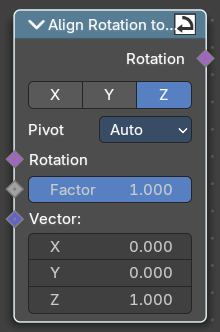
Aligns a rotation to a vector.
Inputs
| Entry | What it does |
|---|---|
| Rotation | The input euler rotation vector. |
| Factor | The factor to align the euler value to the vector. |
| Vector | The vector to align to. |
Properties
Align Axis
To which axis to align the vector.
Pivot
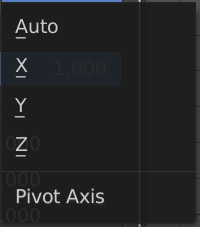
The pivot axis.
Output
Rotation
The output rotation euler angle.
Axes to rotation
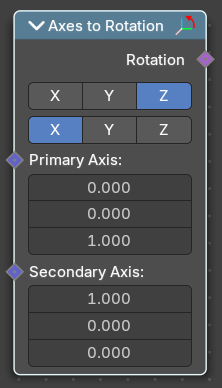
Creates a rotation from a primary and a secondary axis. The axis should be ideally orthogonal.
| Entry | What it does |
|---|---|
| Inputs | Primary Axis: The axis to rotate around. · Secondary Axis: The secondary axis that gives the alignment. |
| Properties | Primary axis: Which axis to rotate around. · Secondary Axis: Which axis to align to. |
| Output | Rotation: The output rotation euler angle. |
Axis Angle to Rotation
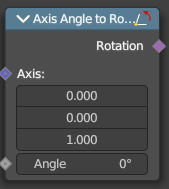
Converts an axis angle to a rotation.
| Entry | What it does |
|---|---|
| Inputs | Axis: The input axis. · Angle: The input angle. |
| Output | Rotation: The output rotation value. |
Euler to Rotation
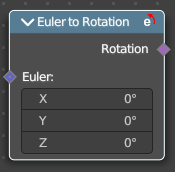
Converts an euler angle to a rotation.
| Entry | What it does |
|---|---|
| Inputs | Euler: The input euler angle vector. |
| Output | Rotation: The output rotation value. |
Invert Rotation
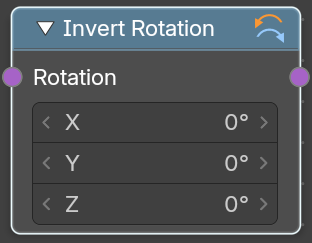
Inverts a rotation
| Entry | What it does |
|---|---|
| Inputs | Rotation: The input rotation vector. |
| Output | Rotation: The output rotation value. |
Mix Rotation
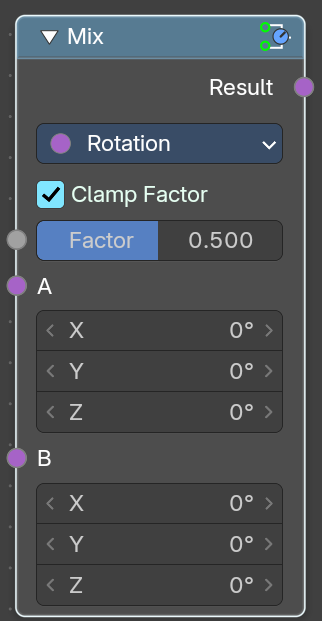
Rotates an euler rotation by another euler rotation.
Inputs
| Entry | What it does |
|---|---|
| Factor | amount of mixing between a and b inputs. |
| A, B | The input. |
Properties
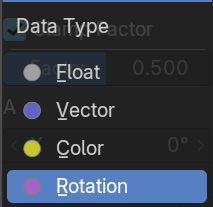
Data Type
What data to calculate.
Outputs
Rotation
The euler angle output.
Rotate Rotation
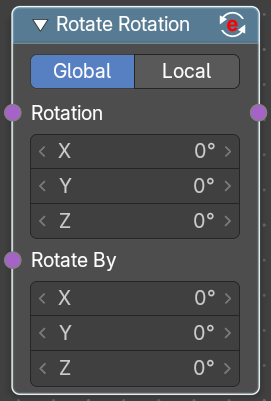
Rotates an euler rotation by another euler rotation.
Inputs
| Entry | What it does |
|---|---|
| Rotation | Use the rotation of an existing geometry. |
| Rotate By | The input rotation. |
Properties
Rotate Space
| Entry | What it does |
|---|---|
| Global | Rotate by the global orientation |
| Local | Rotate by the local orientation |
Outputs
Rotation
The euler angle output.
Rotate Vector
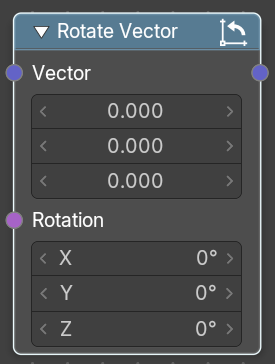
Rotates a vector.
| Entry | What it does |
|---|---|
| Inputs | Vector: The input vector. · Rotation: The input rotation. |
| Output | Rotation: The output rotation value. |
Rotation to Axis Angle
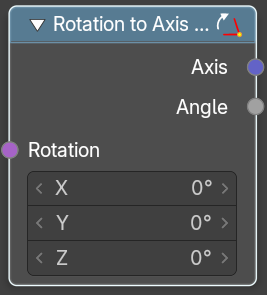
Converts a rotation vector to axis angle.
| Entry | What it does |
|---|---|
| Inputs | Rotation: The input vector. |
| Output | Axis: The axis output. · Angle: The angle output. |
Rotation Euler
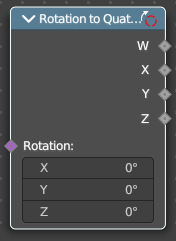
Converts a rotation vector to an euler angle.
| Entry | What it does |
|---|---|
| Inputs | Rotation: The input vector. |
| Output | Euler: The euler angle. |
Rotation to Quaternion
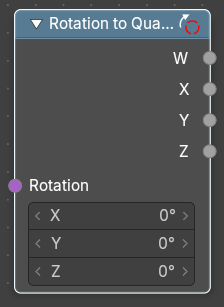
Converts a quaternion to a rotation vector.
| Entry | What it does |
|---|---|
| Inputs | Rotation: The input vector. |
| Output | W, X, Y, Z: The single output values of the quaternion. |
Quaternion to Rotation
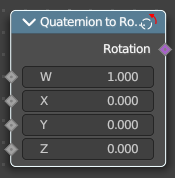
Converts a rotation vector to a quaternion.
| Entry | What it does |
|---|---|
| Inputs | W, X, Y, Z: The single input values of the quaternion. |
| Output | Rotation: The output rotation. |